Teach robots to
sense and act.
From understanding an algorithm to a robot’s first step.
Connect perception, learning, and control, from simulation to the real world.
Learn and explore
From understanding to experimenting.
Start with the big picture, understand the principles, then build a project.
See embodied AI as a whole.
Learn the concepts, history, tasks, and platforms of embodied AI, and find papers, datasets, and open source tools.
- What is embodied AI
- Tasks and platforms
- Papers and datasets
Understand how robots think.
Build a foundation in embodied AI through decision making, motion control, and perception.
- Robotics and ROS2
- Reinforcement learning
- Vision-language-action models
Run an experiment. Bring algorithms to life.
Follow a complete project chapter by chapter, or choose a demo to test methods in simulation and on real robots.
- Quadruped robots
- LeRobot
- MicroDuck
Featured projects
Put your knowledge in motion.
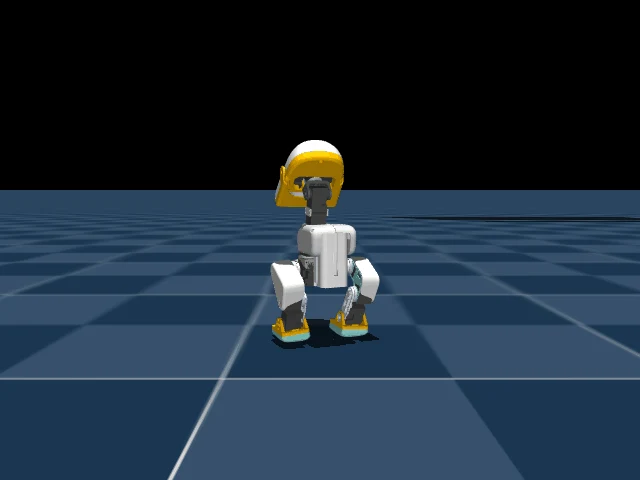
Biped locomotion / Reinforcement learning
MicroDuck biped
Explore walking, standing up, and wheeled motion, from PPO training to action playback.
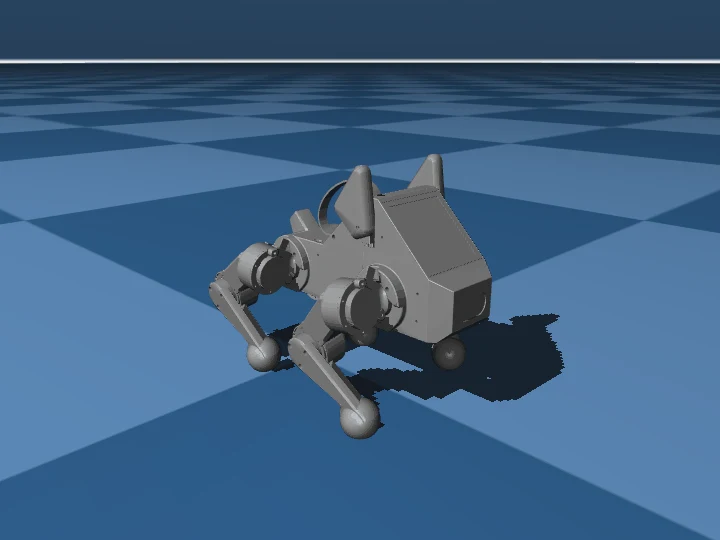
AMD projects / Quadruped control
Explore the Pupper quadruped
Explore reinforcement learning for Pupper locomotion and VLA experiments on AMD hardware.
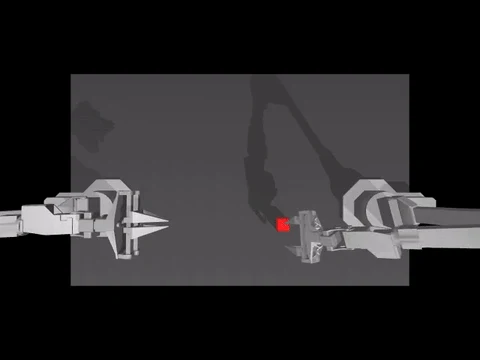
Bimanual coordination / Imitation learning
ACT bimanual training
Train policies with ALOHA simulation data and evaluate bimanual manipulation.
Interactive experiments
Try it. See how it works.
Explore control and kinematics in your browser, with no setup required.
PD control
Tune your first controller
Adjust the gains and see how response, overshoot, and stability change.
Open experimentForward kinematics
See how joints move
Rotate the joints and explore how foot position relates to coordinate frames.
Open experimentInverse kinematics
Move a foot to its target
Move the target to explore the reachable workspace of a robot leg.
Open experimentLEARN WITH DATAWHALE
Every reproduction moves open source forward.
Share a result, fix a typo, or ask a useful question.
Your learning experience can be someone else’s starting point.